Dexterous In-Hand Object Pose Reaching with Learned Safety Filters
arXiv
EECS PhD student at UC Berkeley, advised by Claire Tomlin and Iman Soltani. I work on robot learning, and I’m interested in dexterous manipulation, active perception, and learning safety for high-dimensional systems.
arXiv
ICRA 2026
ICLR 2026
arXiv
CoRL 2025
ICRA 2025
CoRL 2024
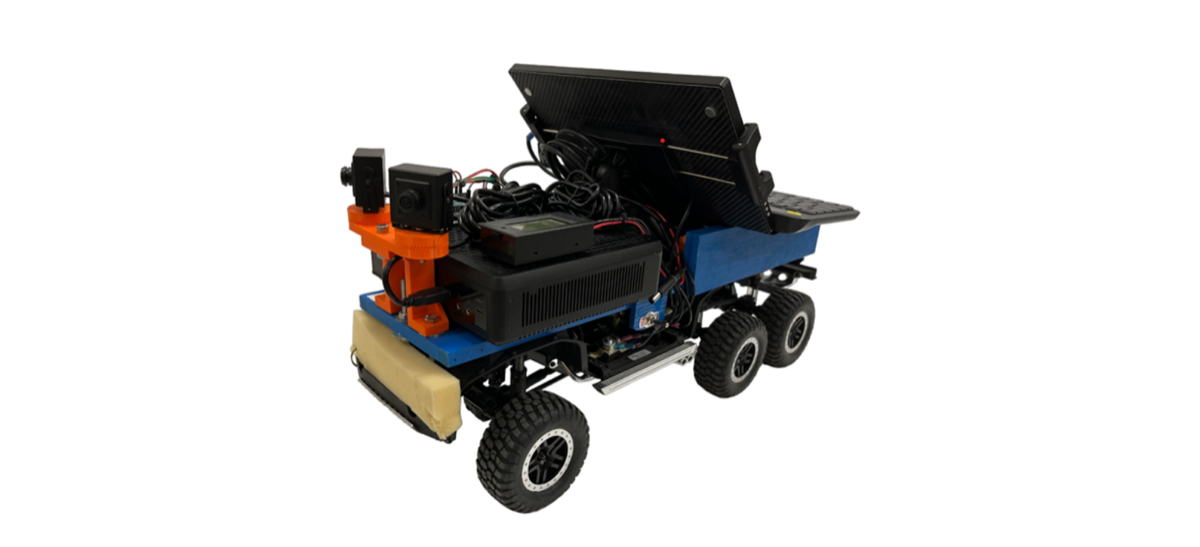
IEEE RA-L 2024
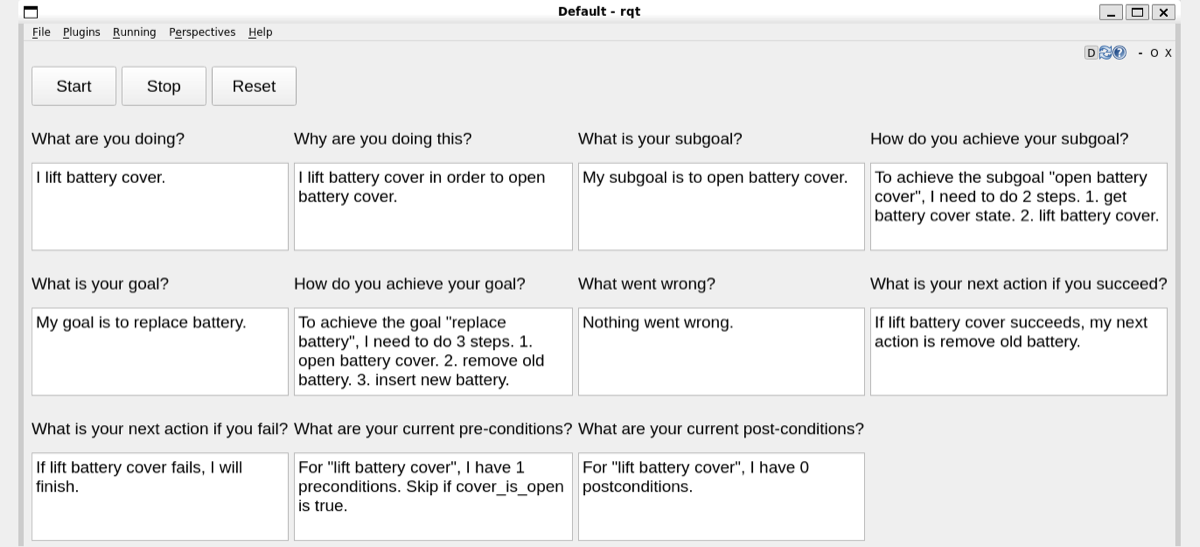
HRI 2024 (Late-Breaking Report)
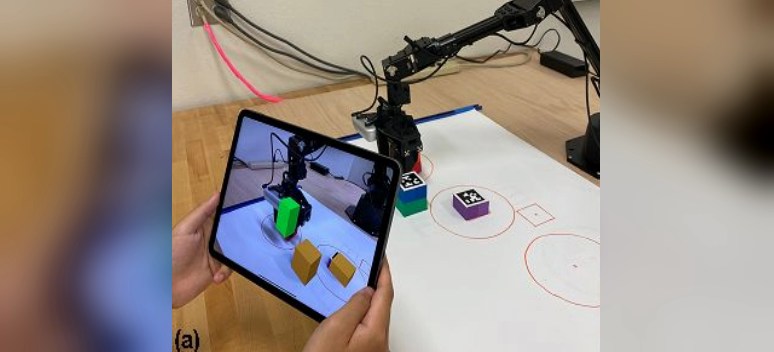
AHFE 2024 · Best Paper Student Award
Control any robot arm in MuJoCo with operational space control.
ROS workspace for UR5e robots in the HRVIP Lab and HOMESTRI.
ROS driver for the OnRobot RG2-FT gripper.
ROS driver for the DH Robotics AG95 gripper.
ROS environment for Aubo robots in LARA.
ROS environment for ViperX 300 arms.
Unity 2D side-scrolling game (ECS 189L group project).
React app that visualizes sorting, graph, and maze algorithms.
Twitter-like app built with React, Redux, and Firebase.